Precision Tool & Asset Location
Real-Time Spatial Intelligence for Critical Environments.
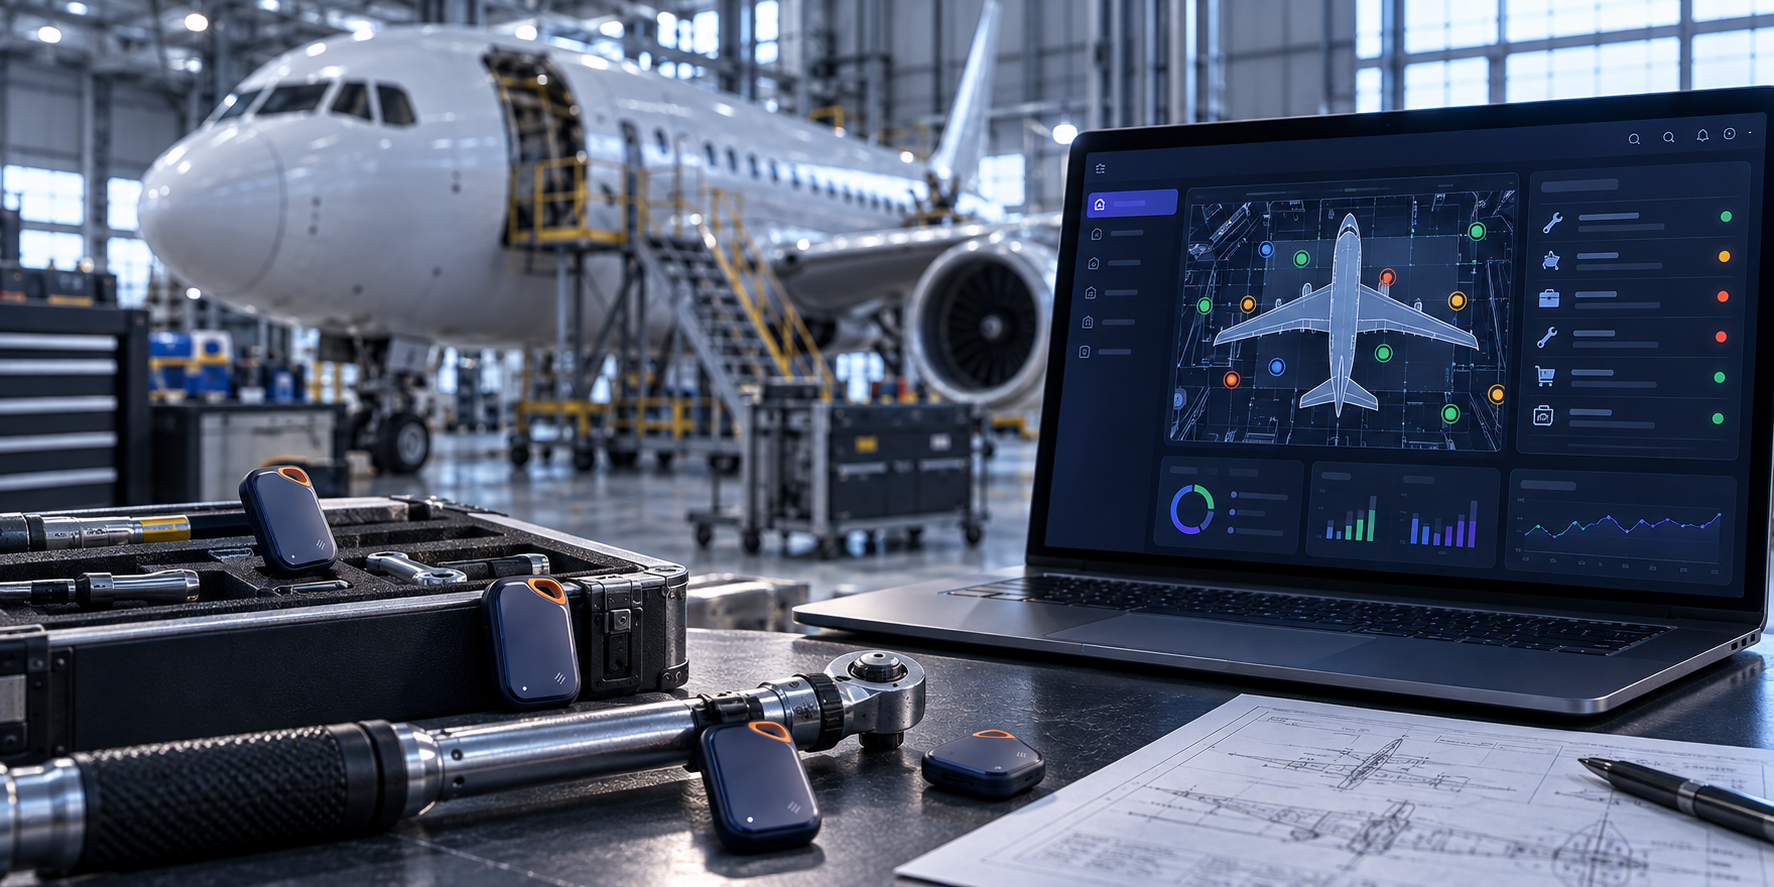
A UWB-based real-time location system engineered to locate, monitor and account for tools and critical assets across complex operational environments.
System at a Glance
UWB
Precision Ranging
RTLS
Real-Time Location
3D
Spatial Positioning
ZONES
Defined Operational Areas
TOOLS
Asset Accountability
FOD
FOD-Risk Reduction
The Operational Problem
Critical tools shouldn't disappear inside complex operational environments.
- In aircraft hangars, depots and large technical facilities, knowing an asset is "somewhere in the building" is not operationally useful.
- Tool accountability depends on knowing exactly where an item is, not approximately where it might be.
- Last known location and zone awareness matter as much as live position when a tool has to be accounted for at the end of a shift.
- Manual tracking doesn't scale across large facilities with constantly moving tools and assets.
System Architecture
From a tagged asset to a real-time position.
Every location starts as a distance measurement, resolved into a position the application can act on.
UWB Tags
Attached to tools/assets
Fixed UWB Anchors
Positioning Engine
Edge / Gateway
RTLS Application
How Location Is Determined
From distance measurements to spatial position.
Each fixed anchor measures its distance to a tag using UWB ranging. With enough anchors and a known anchor geometry, those distances resolve to a precise three-dimensional position.
- 01
UWB Ranging
Each anchor measures precise time-of-flight distance to the tag.
- 02
Anchor Geometry
Known, fixed anchor positions give the distances a spatial reference.
- 03
Position Calculation
Multiple distances resolve to one X, Y, Z position.
- 04
Zone Mapping
The calculated position is mapped against defined operational zones.
Engineering Inside
Engineering inside Precision Tool & Asset Location.
UWB Tags
- UWB radio
- Battery-powered operation
- Tag identity
- Ranging firmware
Anchor Network
- Fixed reference points
- Multi-anchor ranging
- Calibration
- Anchor geometry
Edge & Gateway
- Embedded controller
- Data aggregation
- BLE / Wi-Fi where applicable
- Display / HMI integration
RTLS Software
- Live location
- Zone mapping
- Asset status
- Location history
- Alerts / workflows where implemented
Spatial Intelligence
What the platform shows an operator.
Live Map
Real-time visual position of tracked assets.
Zones
Defined operational areas and boundaries.
Proximity
Awareness of assets near a location or each other.
Location History
Where an asset has been, not just where it is now.
Asset Accountability
Which asset, where, and under whose custody.
Tool Accountability
Location is useful. Accountability is the objective.
Where Spatial Intelligence Matters
Built for environments where tools move constantly.
Aircraft Hangars
Tool and equipment accountability.
Maintenance & MRO
Moving tools and critical assets.
Industrial Facilities
Equipment and asset location across operational areas.
Depots & Warehouses
Location, zones and movement history.
Improved tool accountability can support FOD-risk reduction by helping identify and locate unaccounted tools and assets.
Engineering & Development
Engineering & Development
Architecture
Anchor / Tag Prototype
Multi-Tag Ranging
Calibration
3D Positioning
Operational Validation
Related Engineering Capabilities
The engineering capabilities behind Precision Tool & Asset Location.
Building Something Similar?
Your tracking problem doesn't need to involve aircraft.
If you need to locate tools, equipment, personnel or critical assets across a physical environment, bring us the engineering problem.
Bring Us a Challenge